
Researchers at The Hong Kong University of Science and Technology (HKUST) have developed a robotic arm that replicates aspects of human touch perception.
EmArm integrates a soft optical tactile skin into its rigid mechanical structure, allowing it to detect contact across its upper and lower arms.
By combining tactile feedback with information about its own movements, EmArm can adjust its posture, manipulate objects, and avoid obstacles in real time.
The system can also distinguish between different types of touch, including tickling and patting, supporting research into adaptive manipulation for embodied intelligent robots.
Artificial tactile skin
The robotic arm combines whole-arm tactile sensing with high-precision movement control. The system integrates a soft optical skin into its rigid mechanical structure, allowing it to detect contact, measure applied forces, and respond to physical interactions in real time.
The technology helps robots manipulate objects and navigate around obstacles using touch, including when visual information is unavailable or obstructed.
EmArm takes inspiration from the human body’s bone, muscle, and skin structure. Rather than attaching conventional tactile sensors to the outside of a robot, the researchers embedded a large-area soft optical sensing layer within the arm’s rigid mechanical skeleton.
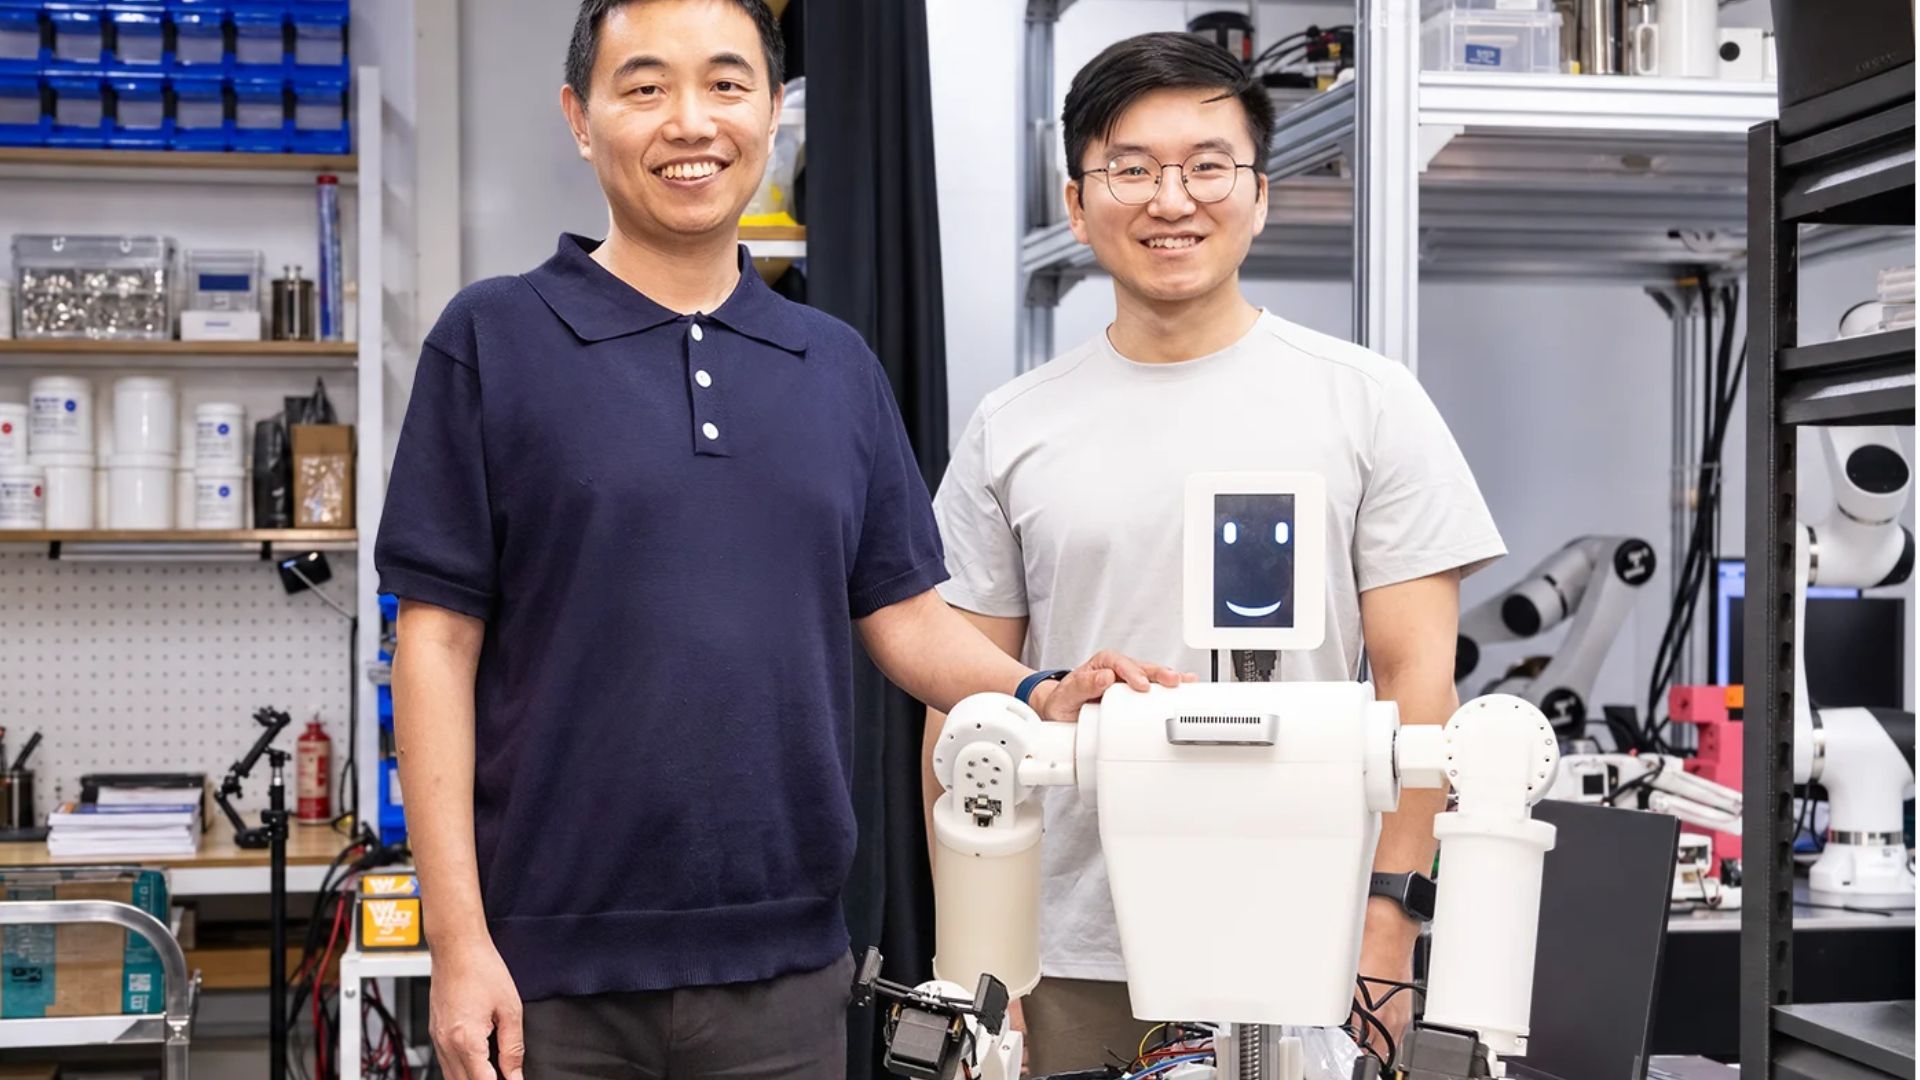
The tactile skin covers more than 71,000 square millimeters across the upper and lower arms. Small cameras measuring less than a millimeter in scale capture changes in the skin caused by contact and analyze the distribution of forces acting on the arm.
This approach allows EmArm to detect physical interactions across a much larger surface than a conventional robotic hand sensor. The system achieves a spatial resolution of 0.085 millimeters, while its two-point discrimination threshold can reach 18.2 millimeters. This threshold describes the minimum separation at which two contact points can be distinguished.
The optical sensing method also reduces the need for complex electrical wiring within the tactile surface. According to the research team, it is resistant to electromagnetic, light, temperature, humidity, and acoustic interference. In experiments involving five types of environmental interference, EmArm maintained a sensing fidelity of up to 97.9 percent.
Smarter robotic manipulation
Integrating a soft sensing layer into a rigid robot can affect its structural strength and movement accuracy. EmArm addresses this challenge by combining the flexible tactile skin with a mechanical framework designed for high-load operation.
Tests showed that the system retained repeat-positioning accuracy comparable to conventional robotic arms. It also withstood pressure loads exceeding 15 kilograms and torsional loads of 7.35 newton-meters. These capabilities allow the arm to combine contact detection with controlled movement without significantly compromising its mechanical performance.
EmArm uses a perception-action loop to translate tactile measurements into movement commands. The framework combines proprioception, which provides information about the arm’s joint positions, with tactile data describing external contact. Its algorithms extract features such as contact location, area, force, and the number of contact points. These measurements are then used by the motion-control system to adjust the arm’s position and applied forces.
In one demonstration, the robot held a basketball positioned away from its center of gravity. By continuously processing tactile and joint-angle information, it adjusted its posture and forces to stabilize the ball. The system also demonstrated obstacle avoidance. When a human hand entered its movement path, even when the obstacle could not be detected visually, the arm identified the contact through touch, stopped its movement, assessed whether the obstruction was temporary or permanent, and replanned its trajectory.
The researchers tested EmArm in human-robot interaction scenarios involving five touch behaviors: stroking, pinching, poking, tickling, and hitting. The system classified these interactions with an accuracy of up to 99.8 percent and generated corresponding responses representing happiness, sadness, curiosity, shyness, or anger.
The researchers suggest that the technology could be extended to robotic legs, torsos, and other body parts. Such integration could help humanoid robots operate more safely in industrial environments, homes, and medical assistance settings, particularly when vision alone is insufficient for detecting contact or navigating obstacles.