CHEONAN — Every movement a person makes is becoming training data for humanoid artificial intelligence.
The Korea Institute of Industrial Technology (KITECH) said on the 14th that a research team led by Ahn Beom-mo, a principal researcher in its AI and Robotics Research Division, has built a full-body motion data collection platform called the Human-to-Humanoid Intelligence Platform (HHIP), which records human movement from head to toe.
Its defining feature is the simultaneous collection of different types of data, including joint movement, the force of a foot striking the ground, and hand motions.
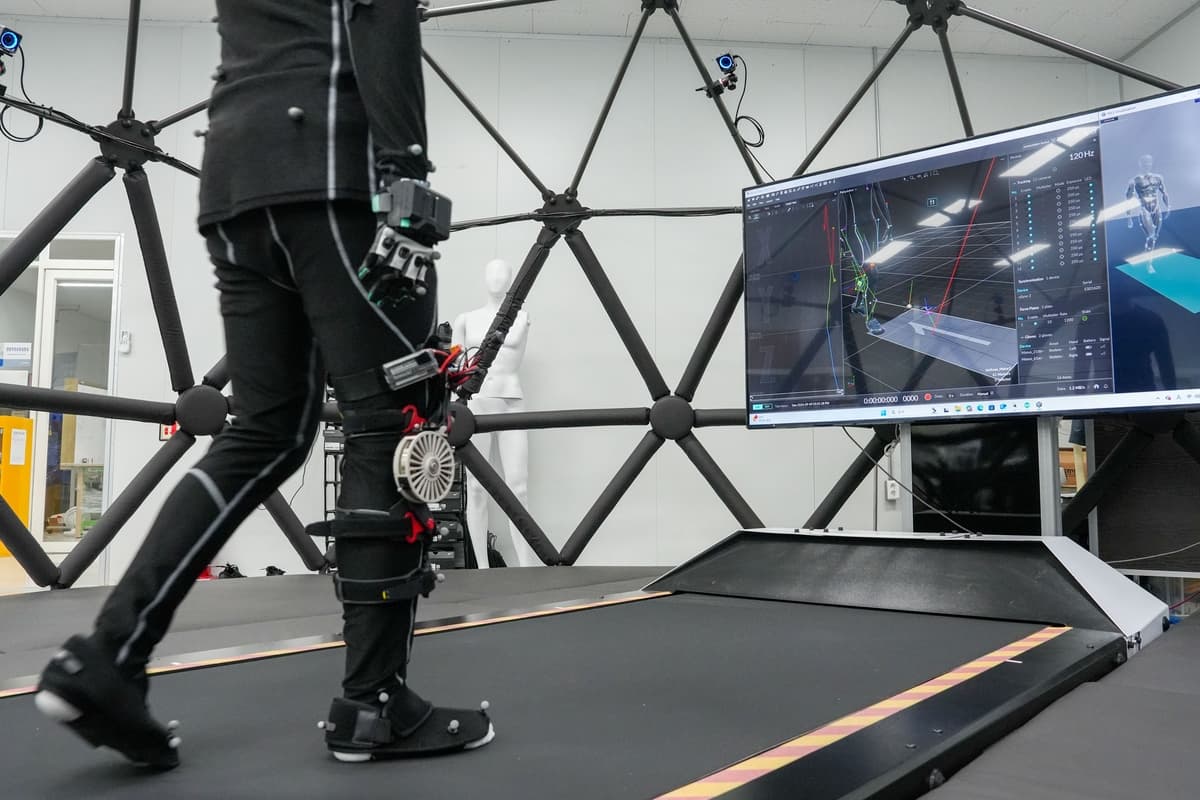
To create a space capable of accumulating full-body data on walking, running, jumping and object-grasping across generations, from older adults to children, the team placed a high-speed treadmill inside a dome-shaped structure and arranged optical motion-capture cameras around its perimeter.
When a person fitted with markers at each joint walks or runs on the treadmill, the cameras track the markers to read joint movement, while force plates in the floor measure the force of each footfall. Glove-type sensors on the hands record finger movement, and electromyography sensors attached to the skin record how much force the muscles exert through their electrical signals.
The treadmill reaches speeds of up to 45 kilometers per hour, allowing the system to measure movements such as sprinting at full effort while wearing a robotic exoskeleton.
To align data from different sensors on a single time axis, the team developed software that sorts and stores all the data together, departing from conventional methods that handled each sensor separately, and verified its accuracy.
Because measurements are taken under identical conditions both without equipment and while wearing a robotic exoskeleton, changes in movement before and after donning the robot can be compared directly.
The team used the platform to verify the performance of AirKnee, described as the world's lightest knee-worn robot. It confirmed whether joints moved at the intended angles while the device was worn and whether walking and lifting objects actually required less effort.
With human motion data now needed to develop humanoid control models, the team is using the platform to collect data on joint movement as people perform tasks.
"We will accumulate data on a wide range of human work movements so that it can be applied not only to humanoids but also to wearable robots and rehabilitation," Ahn said.