প্রতিবেদন লোড হচ্ছে…Why Humanoid Robots Still Struggle With Human-Like Movement | Ayar News
Analytics Insight · সাধারণ
Why Humanoid Robots Still Struggle With Human-Like Movement
২২/১০/২০২৬
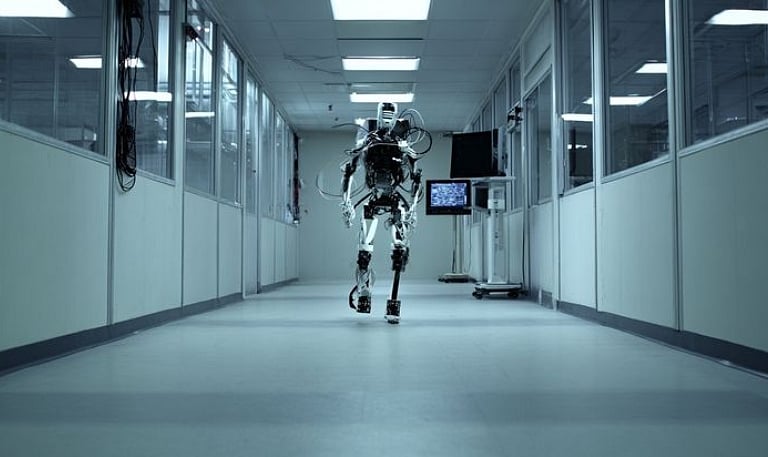
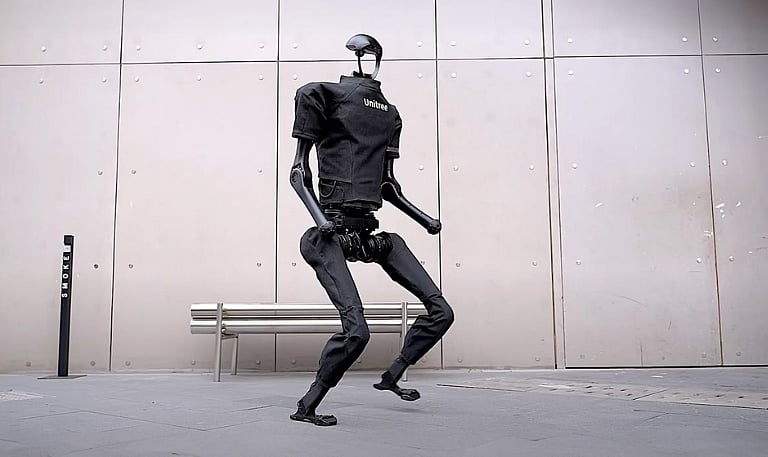
Bipedal balance
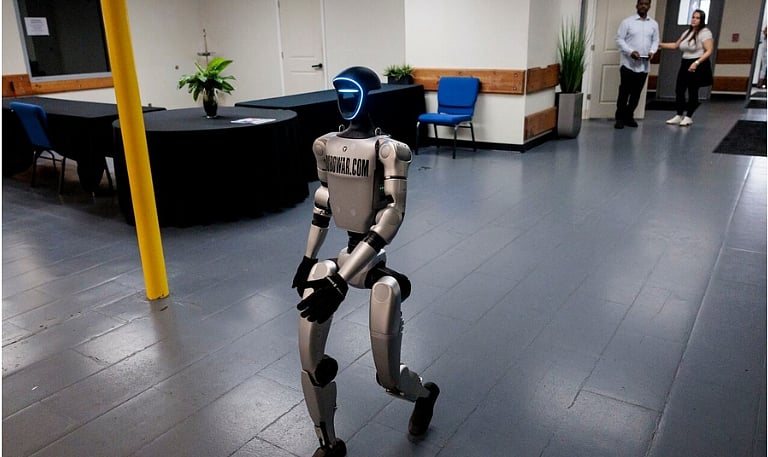
Walking on two legs requires constant balance adjustments. Humanoid robots have a higher centre of gravity, many joints, and a tall body, so small errors can quickly lead to slips, stumbles, or falls.
Complex whole-body control
Humans coordinate legs, arms, torso, and hands automatically. Robots must calculate movement for dozens of joints in real time, while maintaining posture, avoiding collisions, and handling contact with the ground or objects.
Actuator limitations
Human muscles are compact, fast, and highly responsive. Robot actuators must provide high torque, power density, and precise control, but they add weight, consume energy, generate heat, and remain costly to build.
Sensor fusion problems
Natural movement depends on vision, touch, force, and joint-position feedback. A humanoid must combine camera, depth, tactile, force-torque, and joint sensor data quickly and accurately to move safely.
Unpredictable environments
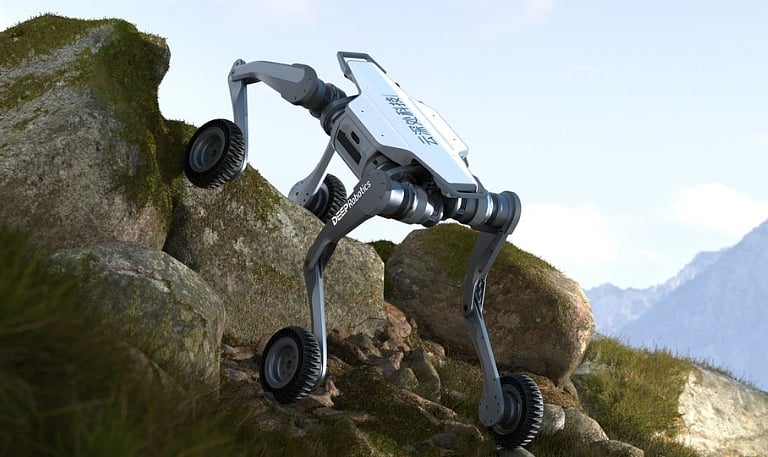
A robot may perform well on flat laboratory floors but struggle outdoors or in cluttered spaces. Changes in surface texture, slopes, obstacles, lighting, and object weight can disrupt stability and grip.
Limited training data
Robots learn movement from human motion data and simulations, but human bodies and robot bodies differ in joint limits, mass distribution, and actuator strength. This makes copying human motion difficult without losing balance.
Separate control systems
Many robots still control walking and arm movements separately. That split can create stiff, disconnected motion, while true human-like movement requires unified whole-body coordination between locomotion and manipulation.