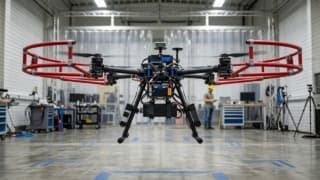
MIT researchers have developed SANDO, a trajectory planning system that guarantees collision-free drone flight. The system works even in unmapped environments with unknown moving obstacles.
SANDO stands for Safe Autonomous Trajectory Planning for Dynamic Unknown Environments. The team published their findings in IEEE Transactions on Robotics. In addition, they released the code on GitHub under the MIT Aerospace Controls Laboratory.
Moreover, the system solves a critical problem for autonomous drones. Most existing planners either assume static environments or avoid moving obstacles without formal safety guarantees. However, SANDO provides a mathematical guarantee that the flight path stays clear of all obstacles.

The system works by building a time-sensitive “safety corridor” around the drone’s path. It first detects, groups, and tracks dynamic obstacles to estimate their future positions. Since the obstacles’ future movements remain unknown, SANDO uses each object’s maximum possible speed to create expanding spheres. These spheres represent every possible position the obstacle could reach.
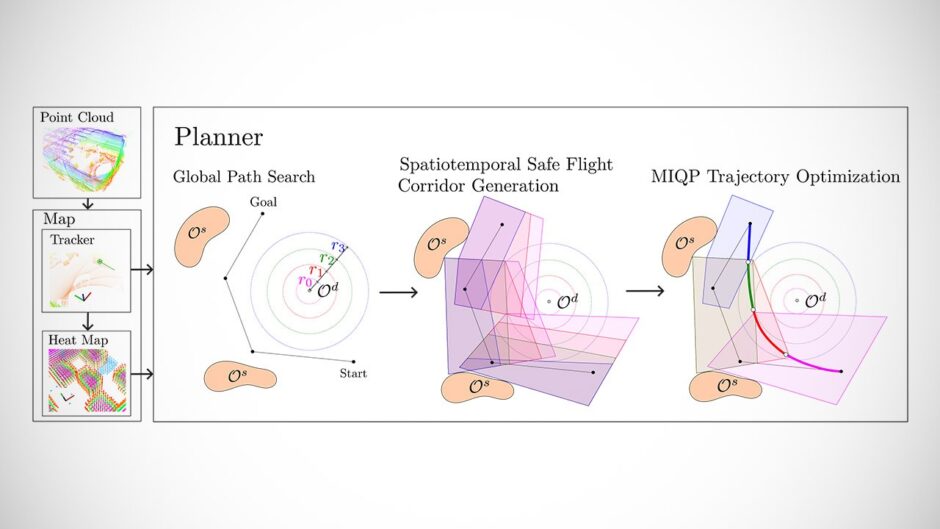
Furthermore, a heat-map-based planner identifies areas with dense obstacle clusters. It then steers the drone toward less congested routes. Consequently, the system optimizes for the fastest safe path to the goal. All processing runs entirely on the drone’s own hardware. As a result, the system continuously updates the corridor and replans in real time.
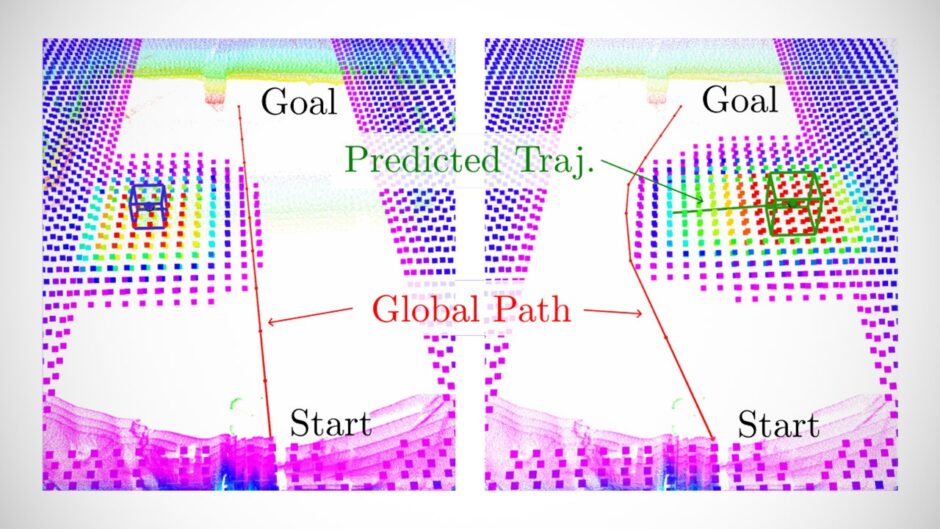
Lead researcher Kota Kondo says the system only needs one input. “The only thing the planner needs to know is the top speed the obstacles could reach,” Kondo explains. Notably, the system requires no prior map of the area.
In addition, the team tested SANDO across 12 real-world flights with a drone using onboard computing and sensors. The drone avoided every moving obstacle in all test conditions. Similarly, simulations showed SANDO reached goals faster than several existing planners while recording zero collisions.
The researchers see applications in search and rescue, mine tunnel exploration, package delivery in crowded areas, and disaster response. Overall, senior author Jonathan How and the team plan to improve computational efficiency and combine SANDO with machine-learning models for plain-language instructions.